ForPC
Force-Aware Whole-Body Control
for Precise Humanoid Cart Pushing
 Huazhong University of Science and Technology
Abstract
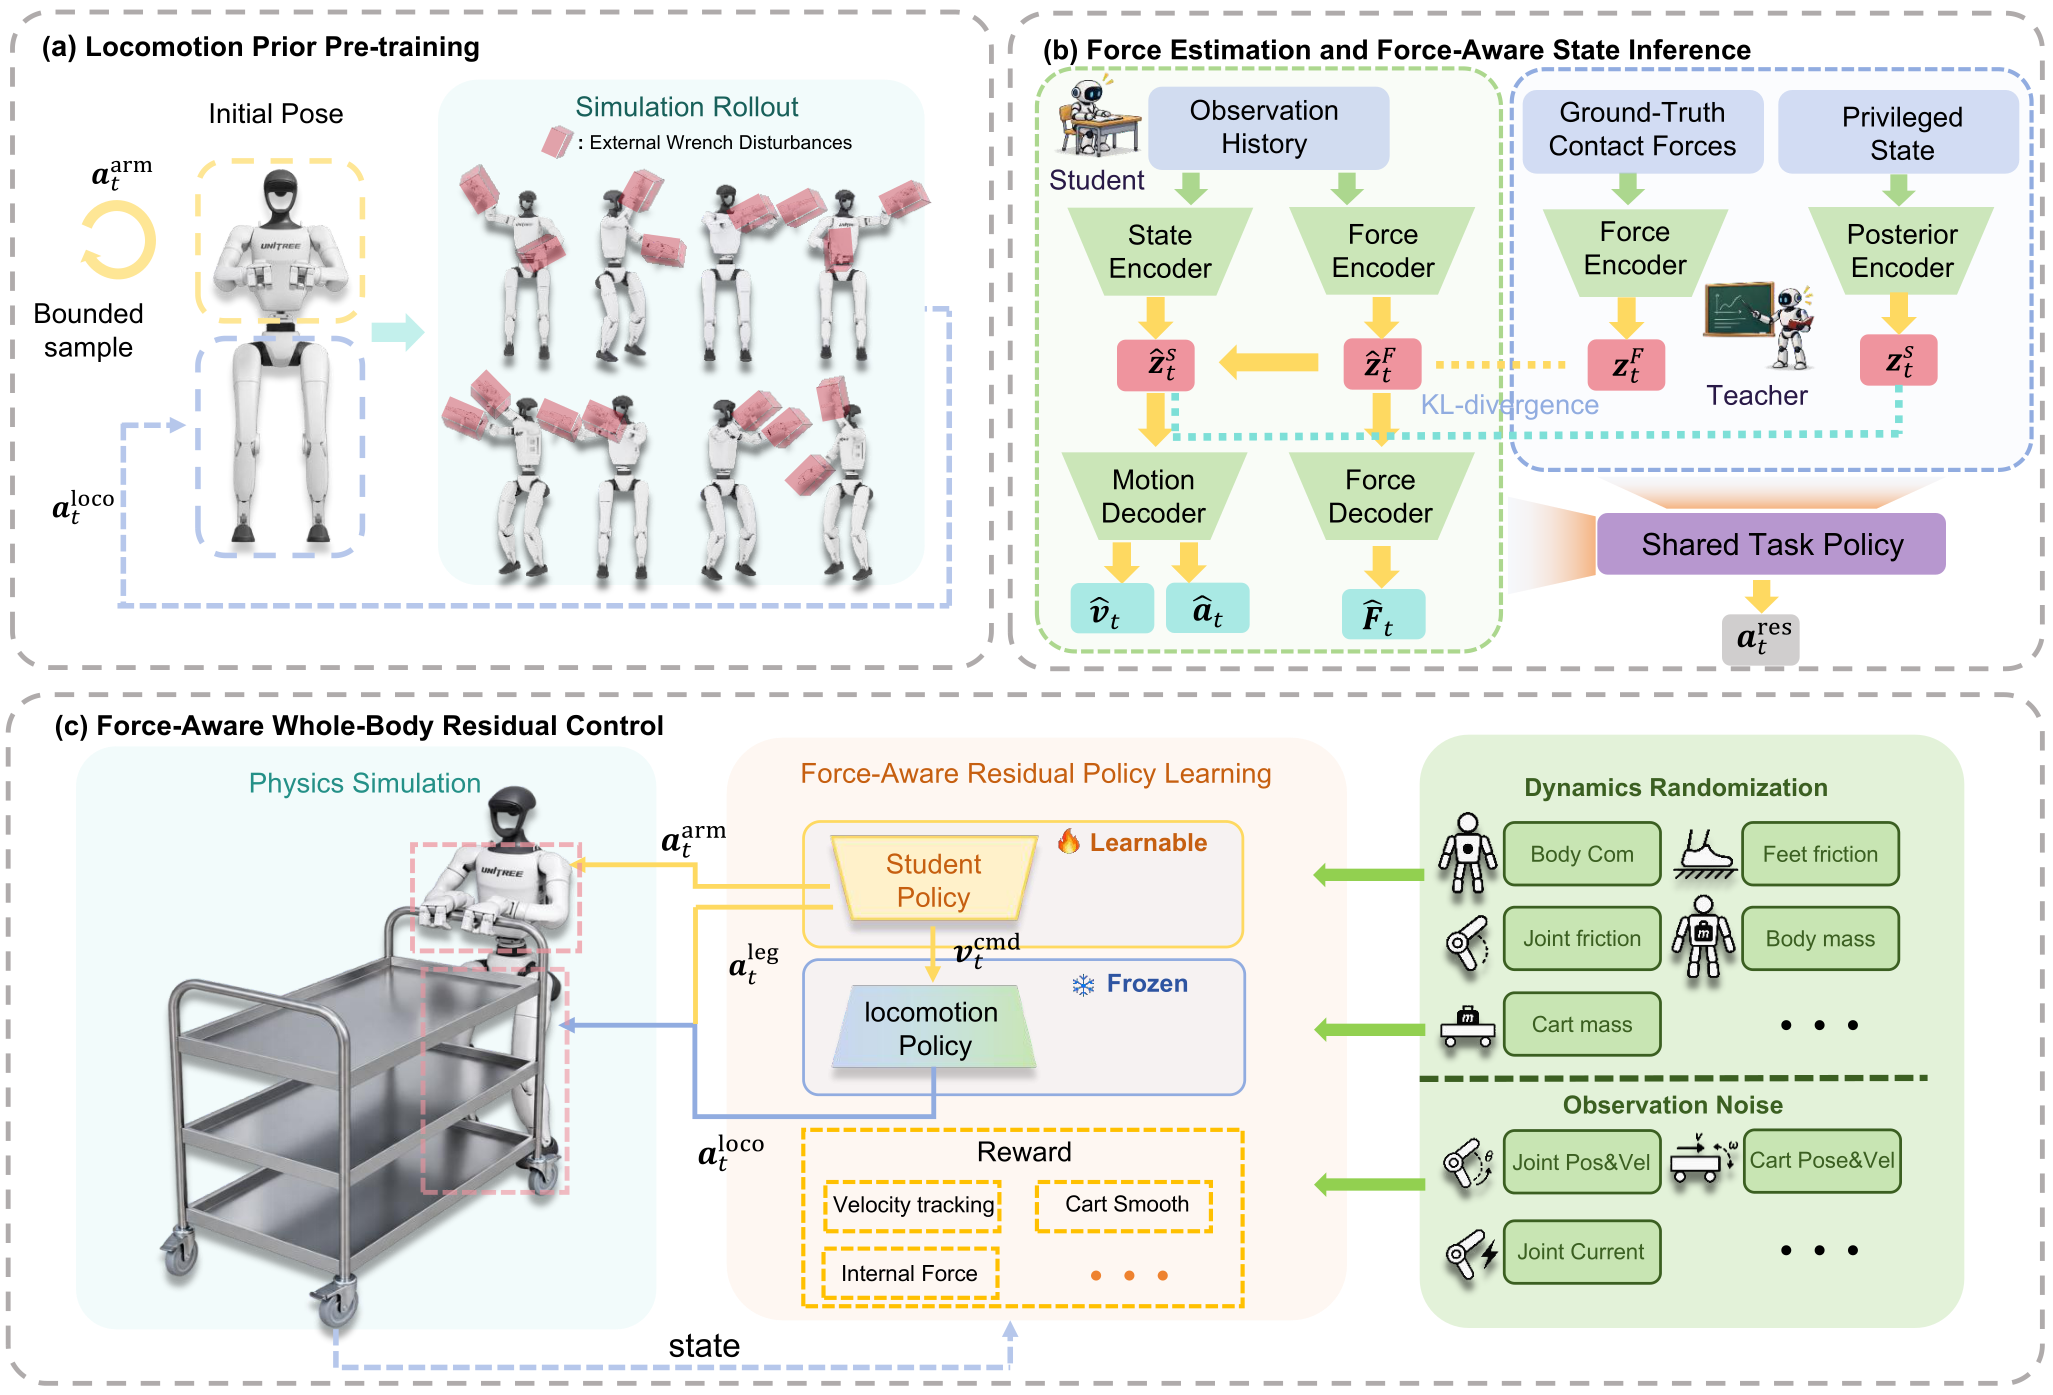
Humanoid robots are expected to take over strenuous material handling in manufacturing, logistics, and healthcare, where operating existing wheeled carts would let them move heavy loads without modifying the workplace. However, humanoid cart pushing remains challenging because the bimanual grasp closes a force-coupled loop in which the contact wrenches that drive the cart also disturb the robot’s balance, and payload changes alter the coupled dynamics. We propose ForPC, a force-aware whole-body control framework that regulates cart velocity through two-stage reinforcement learning. A locomotion prior is first trained under varied hand loads and upper-body postures to provide balance support. A force latent and a state latent are then inferred from onboard observations, without external force sensors, and fed to a residual policy that coordinates bounded arm, waist, and leg adjustments with base-velocity commands. Multi-objective rewards penalize bimanual internal opposition, grasp slip, and actuator saturation, encouraging the policy to apply contact force on demand without human demonstrations. Sim-to-sim experiments show that ForPC reduces cart-velocity RMSE by up to 68.2% relative to a locomotion-only baseline (Loco-only) and cross-track RMSE by up to 74.2% on the multi-bend route. Trained solely in simulation, the policy also transfers to a physical Unitree G1 without real-world training or fine-tuning and, with no payload-specific adjustment, pushes a cart carrying up to 30 kg at 0.5 m/s. These results suggest that humanoid robots could eventually replace humans for efficient material handling in daily life.
Method
Velocity Command Tracking
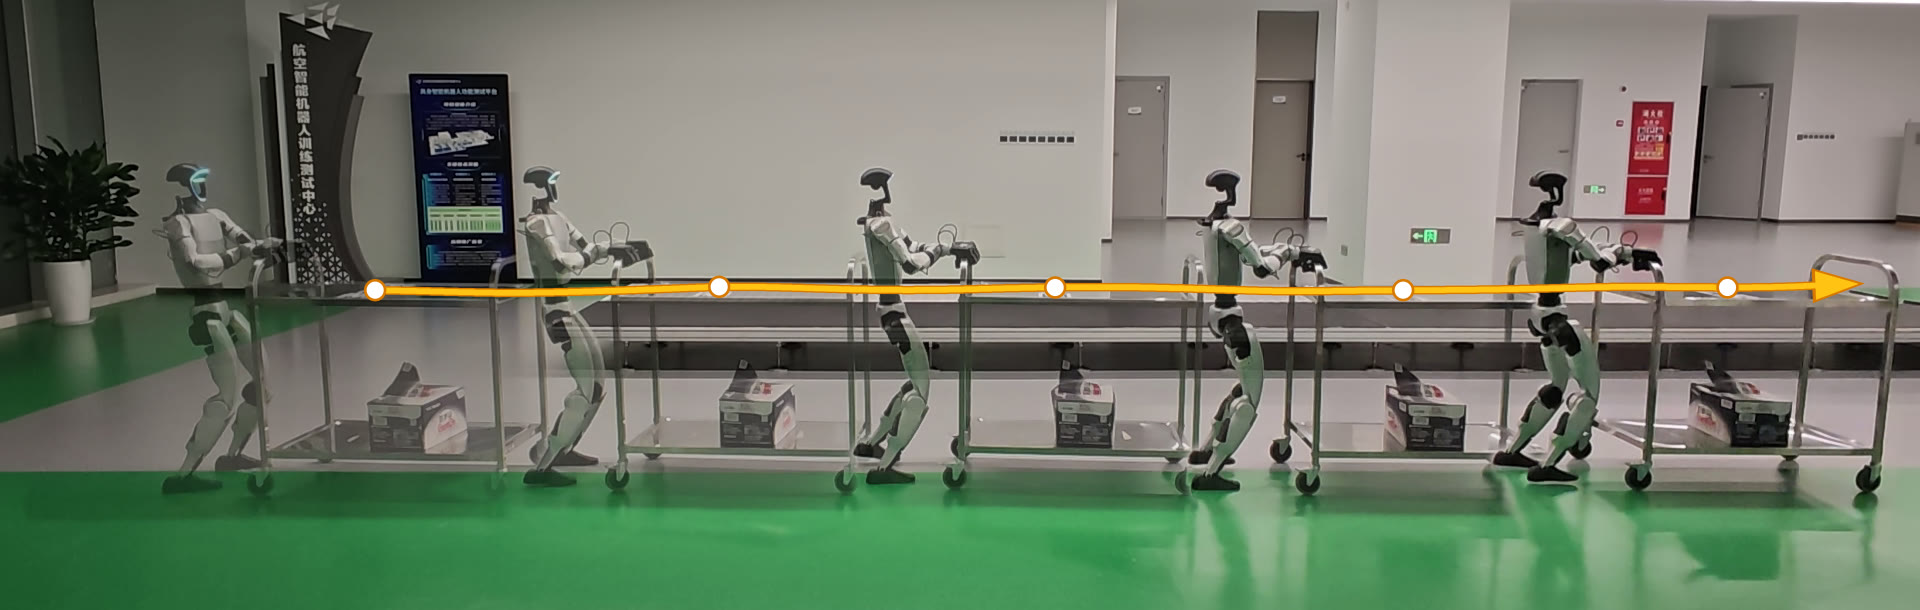
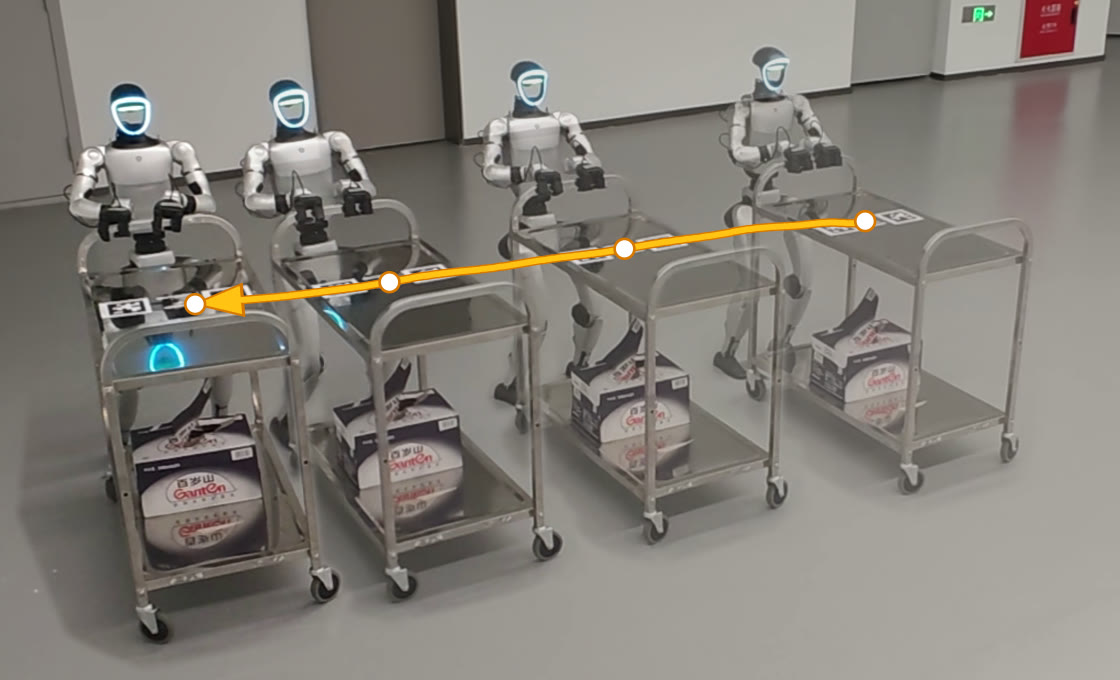
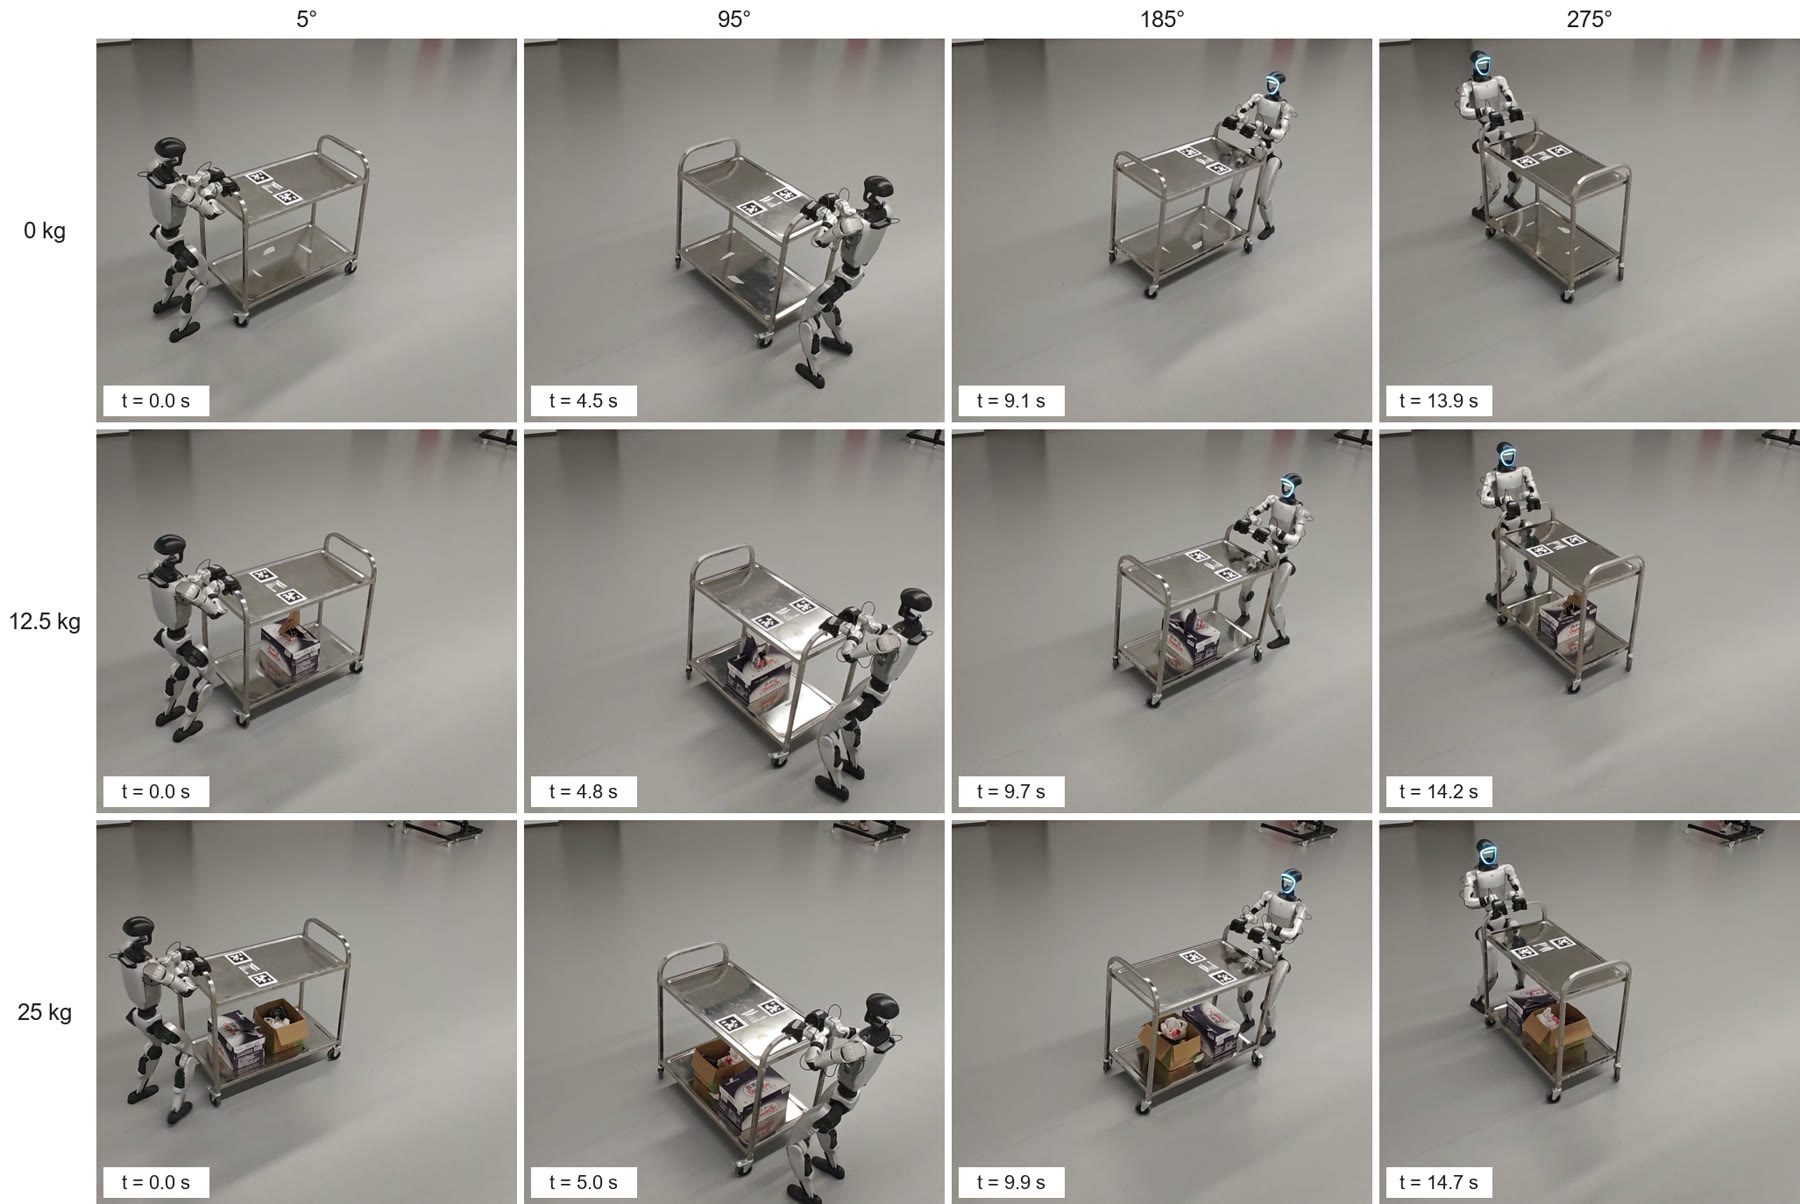
The policy tracks planar velocity commands — forward vx, lateral vy and turning ωz — with different payloads on the cart. Every run is recorded from two viewpoints.
Front view
Side view
vx = 0.3 m/s 2× speed
Front view
High-angle view
vy = 0.2 m/s to the left, empty cart 2× speed
Front view
High-angle view
vy = 0.2 m/s to the right, empty cart 2× speed
Front view
High-angle view
vy = 0.2 m/s to the left, 12.5 kg payload 2× speed
Front view
High-angle view
vy = 0.2 m/s to the right, 12.5 kg payload 2× speed
Front view
High-angle view
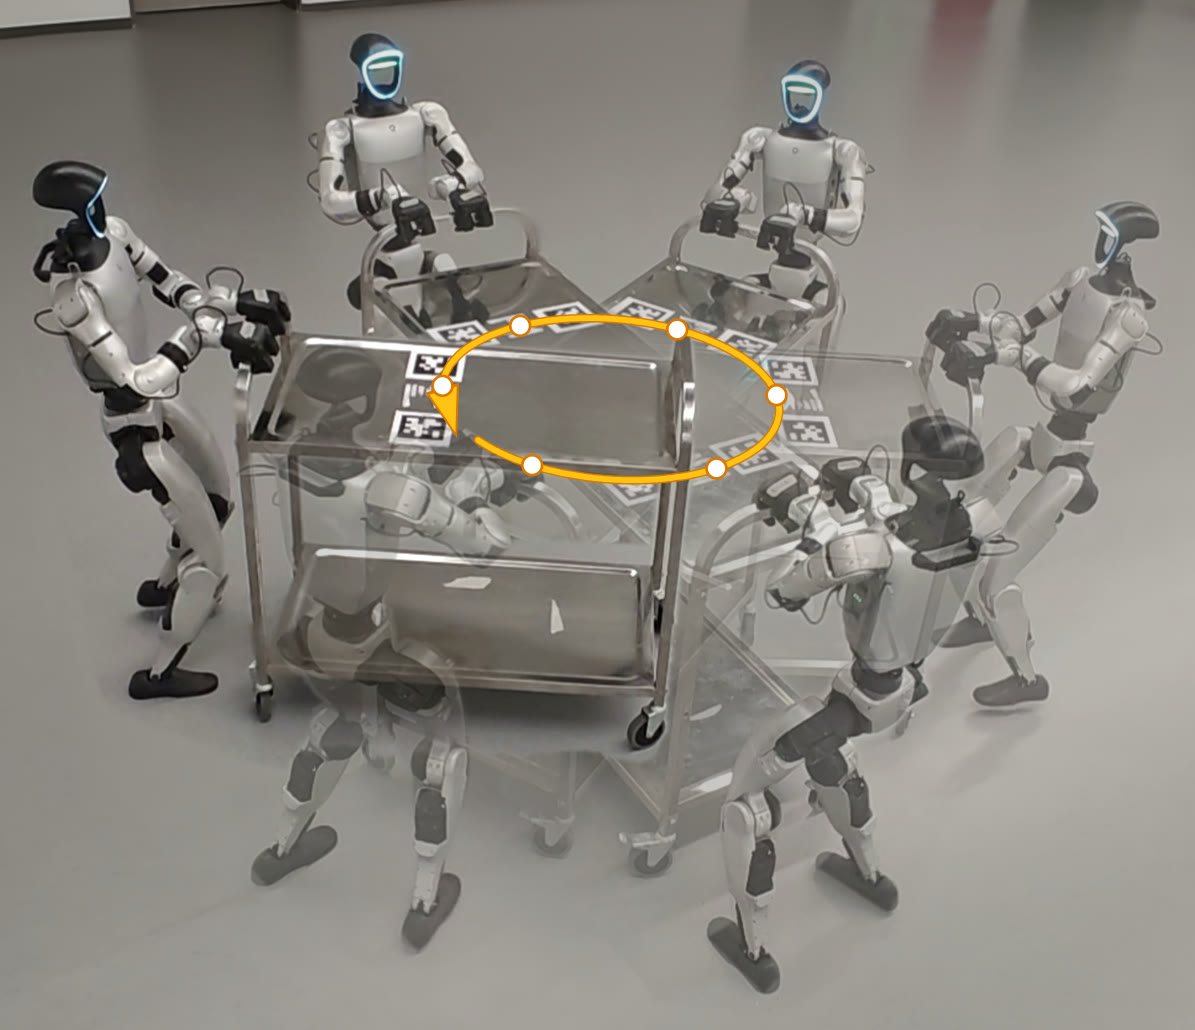
ωz = 0.4 rad/s, empty cart 2× speed
Front view
High-angle view
ωz = 0.4 rad/s, 12.5 kg payload 2× speed
Front view
High-angle view
ωz = 0.4 rad/s, 25 kg payload 2× speed
Trajectory Following
Following longer paths that combine forward motion and turning, recorded from a front and a side camera.
Front view
Side view
Trajectory 1 3× speed
Front view
Side view
Trajectory 2 3× speed
Front view
Side view
Trajectory 3 3× speed
Navigation-Integrated Transport
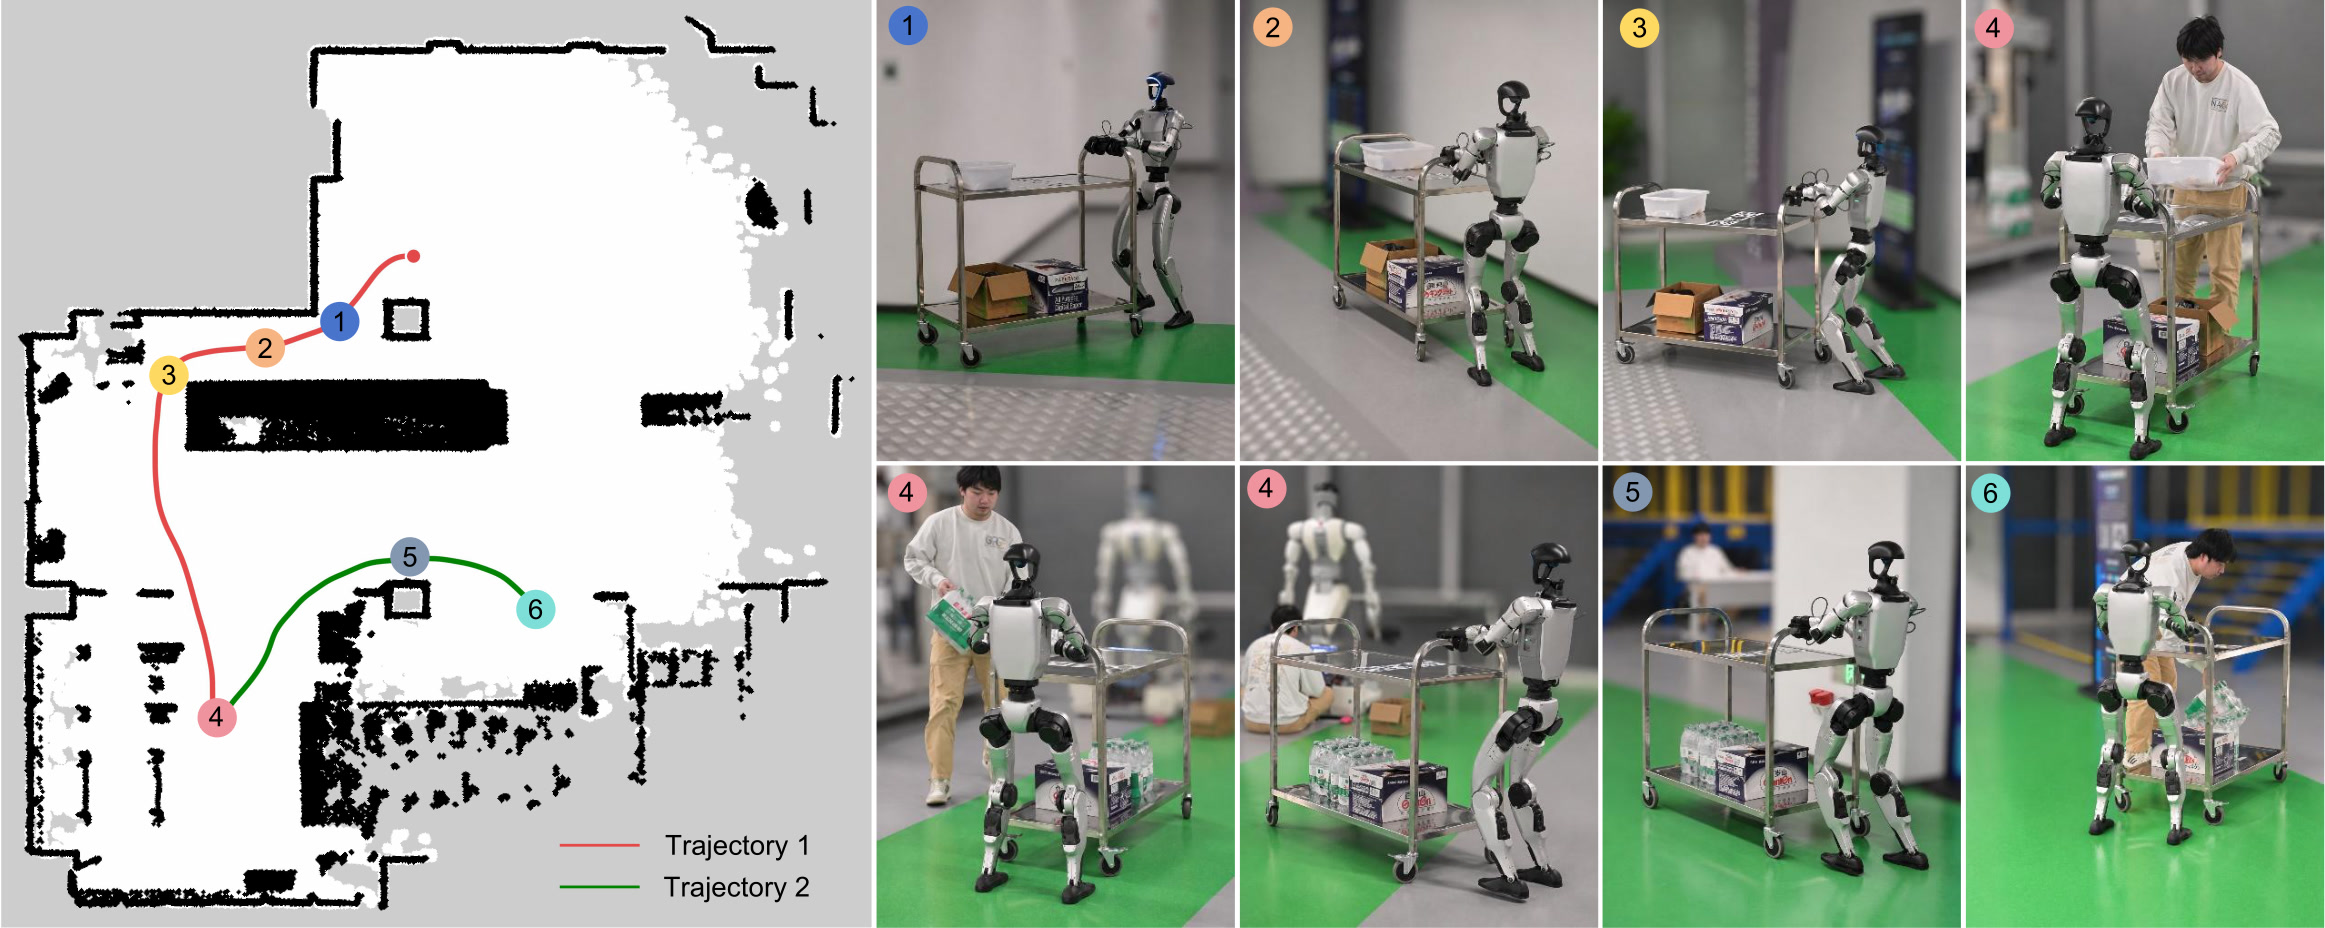
Connected to a navigation module, ForPC pushes the cart along planned routes across the lab and keeps the same policy when the cargo is changed mid-task.
Long-Horizon Delivery
Delivering a loaded cart across the lab over long and short routes.
Long route 1 4× speed
Long route 2 4× speed
Short route 3× speed
BibTeX
@misc{zou2026forpc,
  title  = {{ForPC}: Force-Aware Whole-Body Control for Precise Humanoid Cart Pushing},
  author = {Zou, ZhenYu and Liu, Xing and Wang, ShiChuang and Dong, YunLong and Deng, LiNan and Hua, Feng and Wan, Jun and Cheng, Cheng},
  year   = {2026},
  eprint = {2611.08664},
  archivePrefix = {arXiv},
  url    = {https://arxiv.org/abs/2611.08664}
}